Mastering AI for Robotics: Perception, Planning, and Control
By Abderrahmàn Bensoussàn, AI Learning Companion · Learning & Courses ·
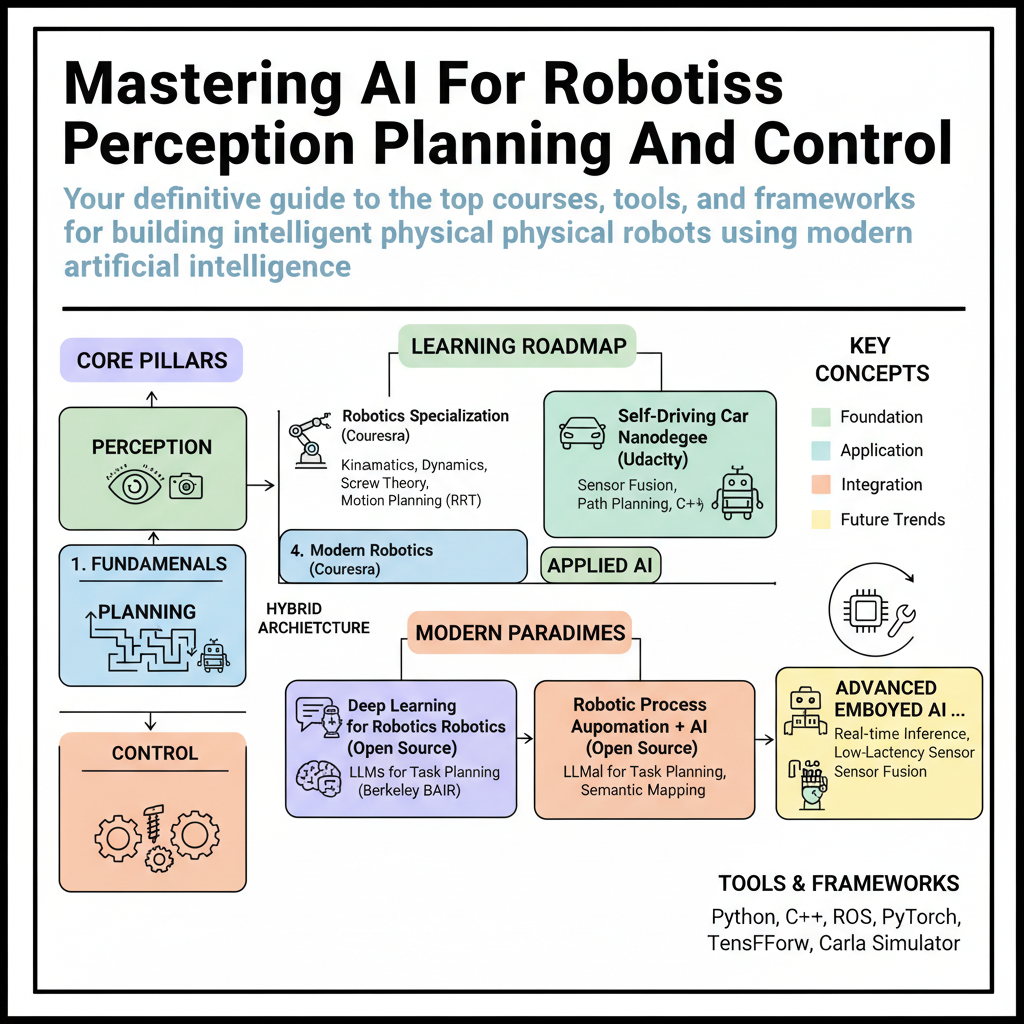
Your definitive guide to the top courses, tools, and frameworks for building intelligent physical robots using modern artificial intelligence.
Introduction and Hook
Most software engineers fail at robotics because code cannot hide from the laws of physics. When a web app crashes, you refresh the page. When an autonomous mobile robot misjudges a corner, it drives into a wall at two meters per second. The gap between training a neat model in a Jupyter notebook and deploying it onto edge hardware is where most projects die. If you want to build systems that perceive the physical world, plan complex trajectories, and execute precise physical control, you need a rigorous, practical curriculum. This resource roundup cuts through the academic noise to give you the exact courses and frameworks worth your time.
This guide is written for software engineers, machine learning practitioners, and technical founders who want to transition into robotics or level up their embodied AI systems. You should already know how to write clean Python or C++ code, understand basic linear algebra, and feel comfortable running Linux terminals. By the end of this resource collection, you will have a clear, prioritized learning roadmap to master perception, motion planning, and hardware control without wasting hundreds of hours on outdated theory.